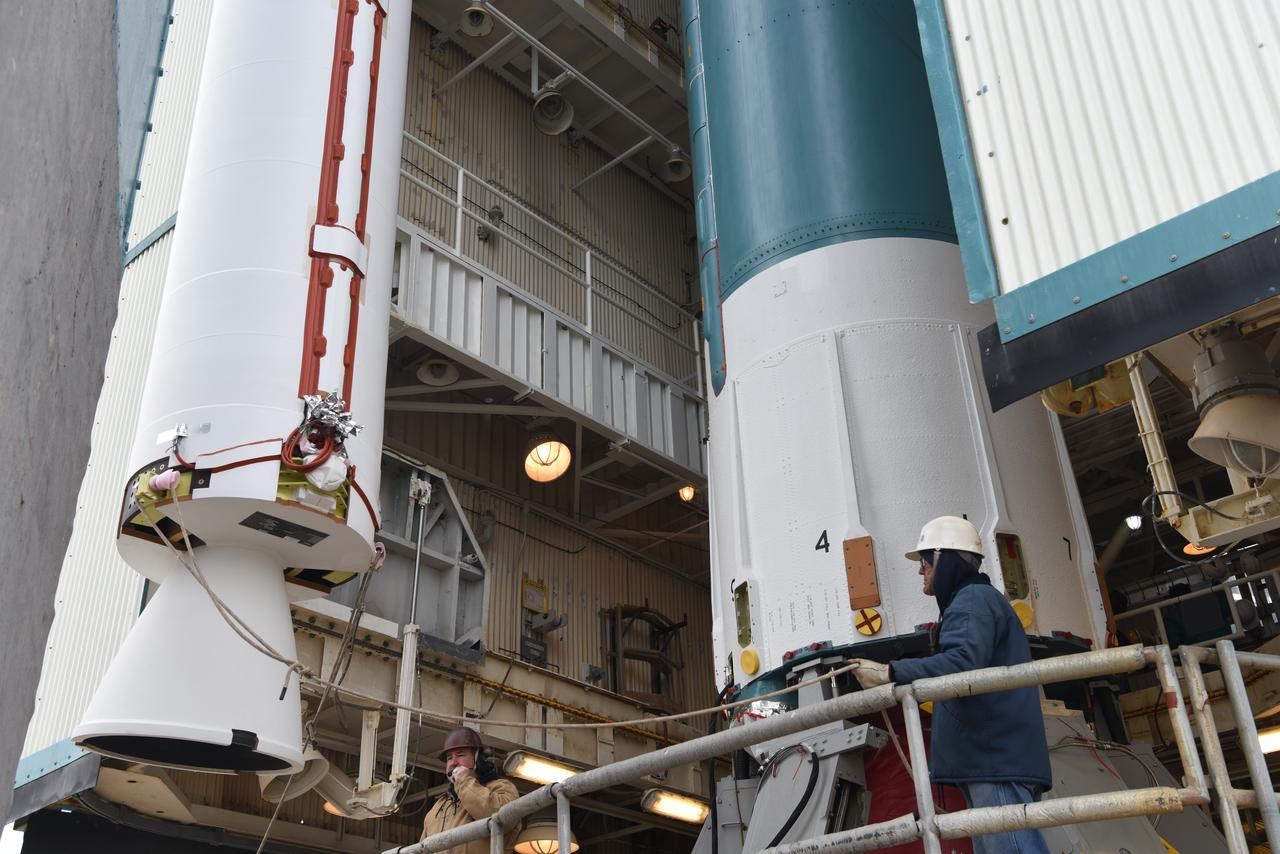
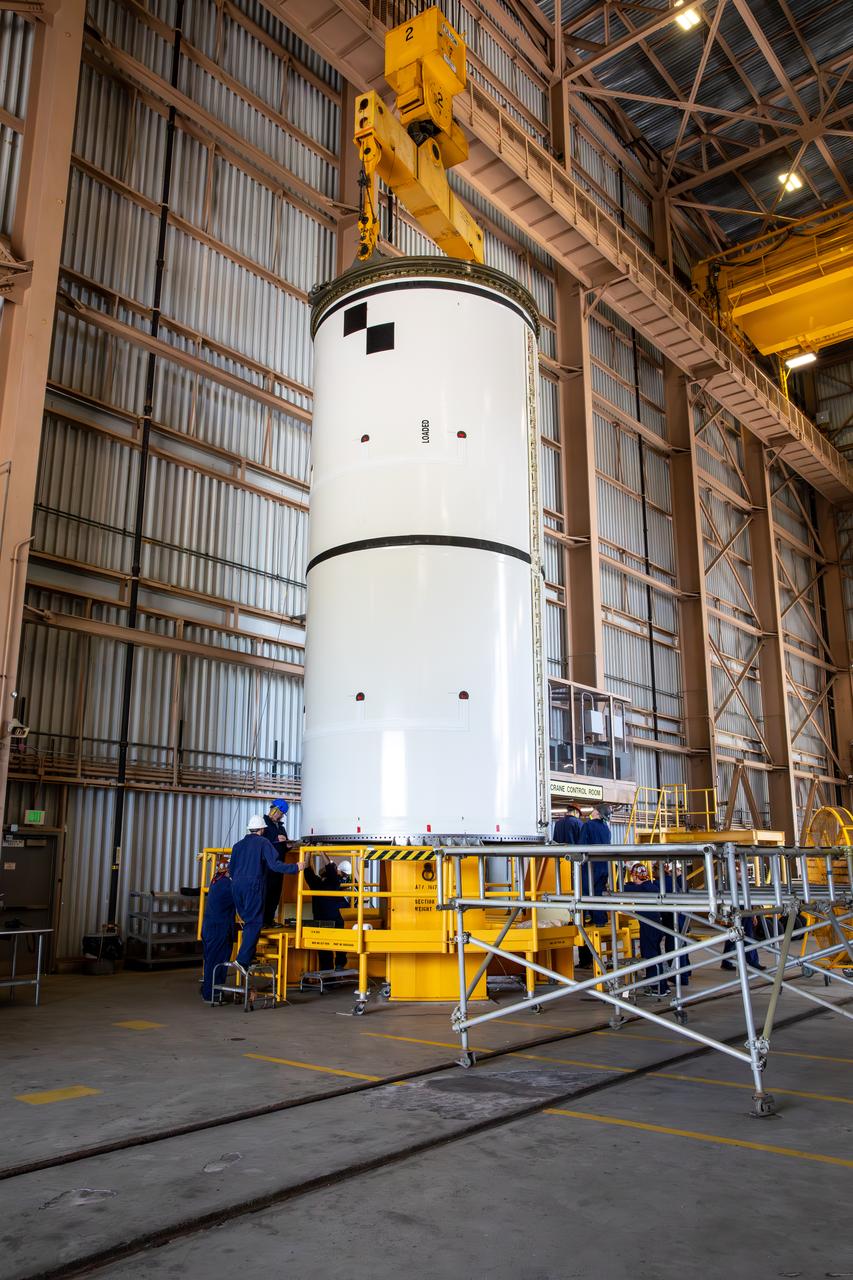
Delta II ICESat-2 SRM Lift and Mate
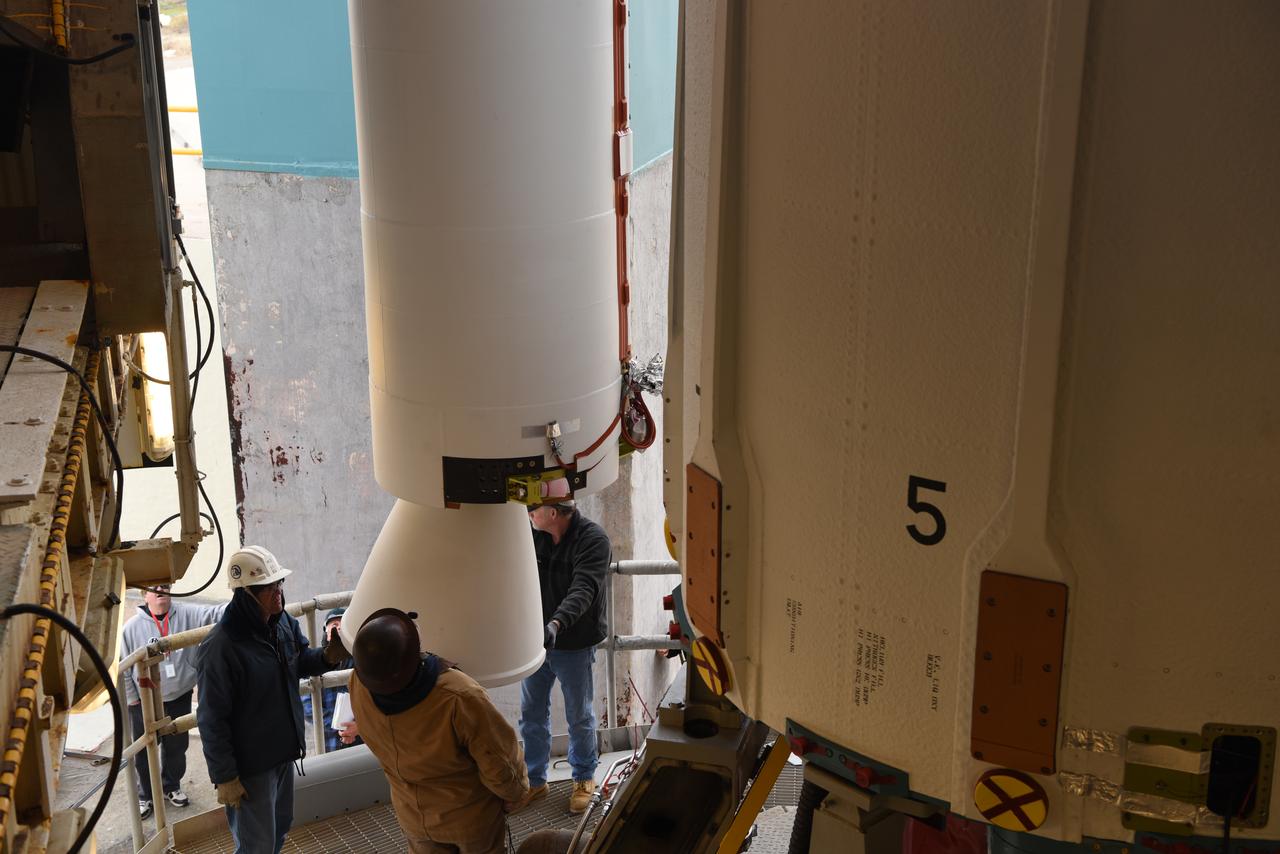
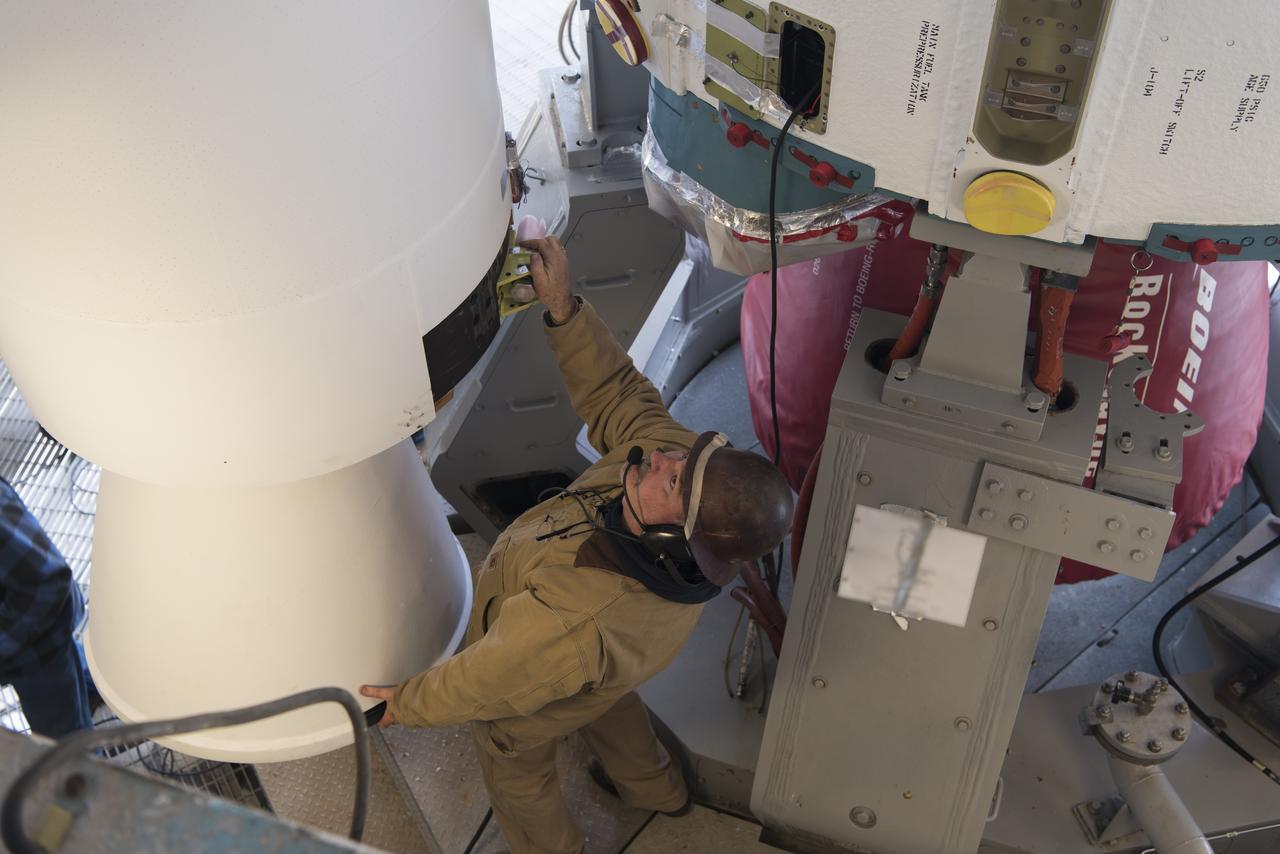
The solid rocket motor for mating to the United Launch Alliance Delta II launch vehicle is lifted up at the Vertical Integration Facility (VIF) at Space Launch Complex 2 on June 14, 2018, at Vandenberg Air Force Base in California. The solid rocket motor will be attached to the rocket. NASA's Ice, Cloud and land Elevation Satellite-2 (ICESat-2) will launch on the final Delta II rocket. ICESat-2 will measure the height of a changing Earth, one laser pulse at a time, 10,000 laser pulses a second. The satellite will carry a single instrument, the Advanced Topographic Laser Altimeter System. ICESat-2 will help scientists investigate why, and how much our planet's frozen and icy areas, called the cryosphere, is changing in a warming climate.
- Date
- 2018-06-14
- Photographer / author
- USAF 30th Space Wing/Mark Mackle
- Collection
- KSC
- Archive
- NASA Image and Video Library
- Type
- photograph
Public domainsafest
Reason: a NASA work: not copyrighted in the United States.
Read from: NASA media usage guidelines: NASA material is not copyrighted in the US unless noted; no third-party credit or mark found.
Credit line
"Delta II ICESat-2 SRM Lift and Mate" (2018-06-14). NASA/KSC/USAF 30th Space Wing/Mark Mackle. Public domain. https://images.nasa.gov/details/VAFB-20180614-PH_MNM01_0048Need photos for a whole script? Add Find Any Photo to Claude and ask for this one by its id: 82976.
More like this
Delta II ICESat-2 SRM Lift and Mate
2018-06-14 · NASA Image and Video Library
Delta II ICESat-2 SRM Lift and Mate
2018-06-14 · NASA Image and Video Library
ICESat-2 Prelaunch
2018-09-14 · NASA Image and Video Library
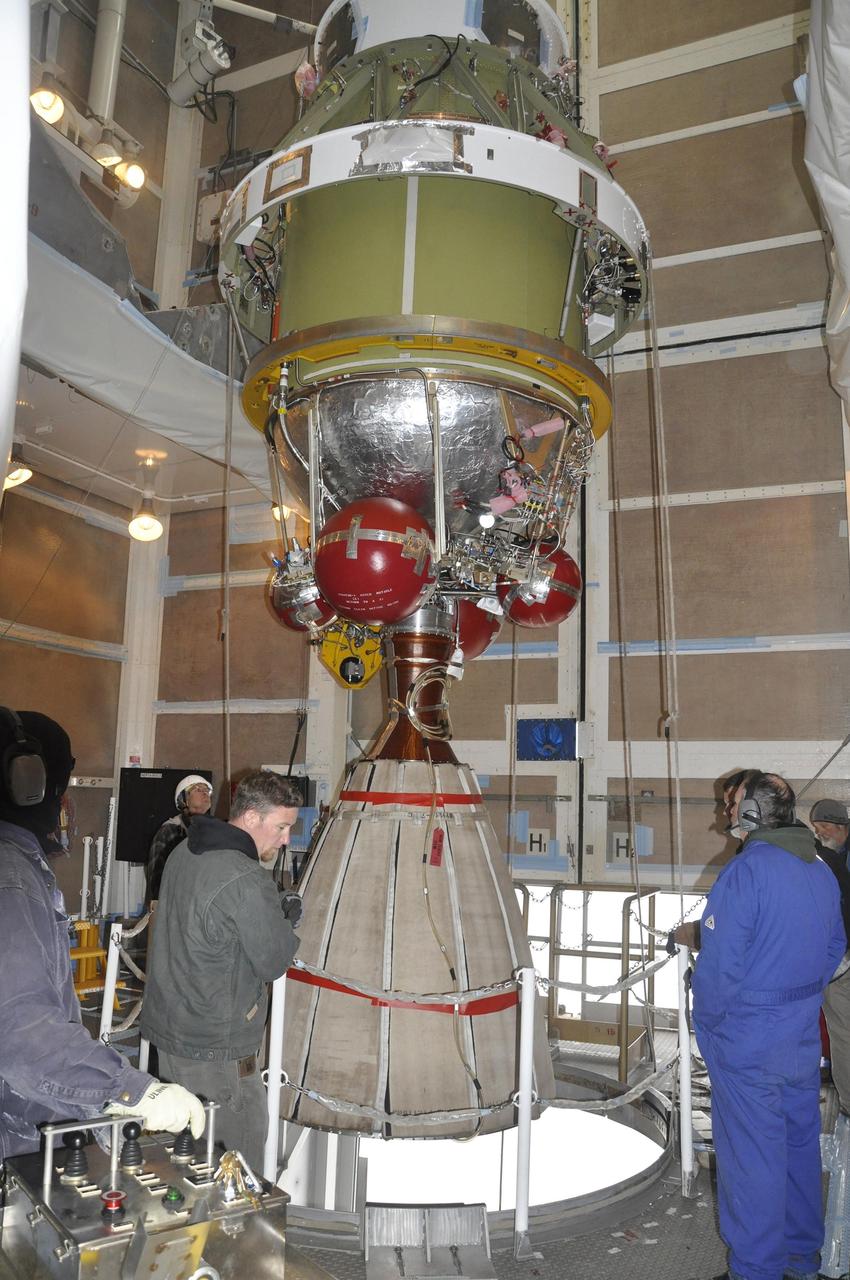
Lifting NASA OCO-2 Delta II Launch Vehicle Second Stage into Position for Mating
2014-04-15 · NASA Image and Video Library
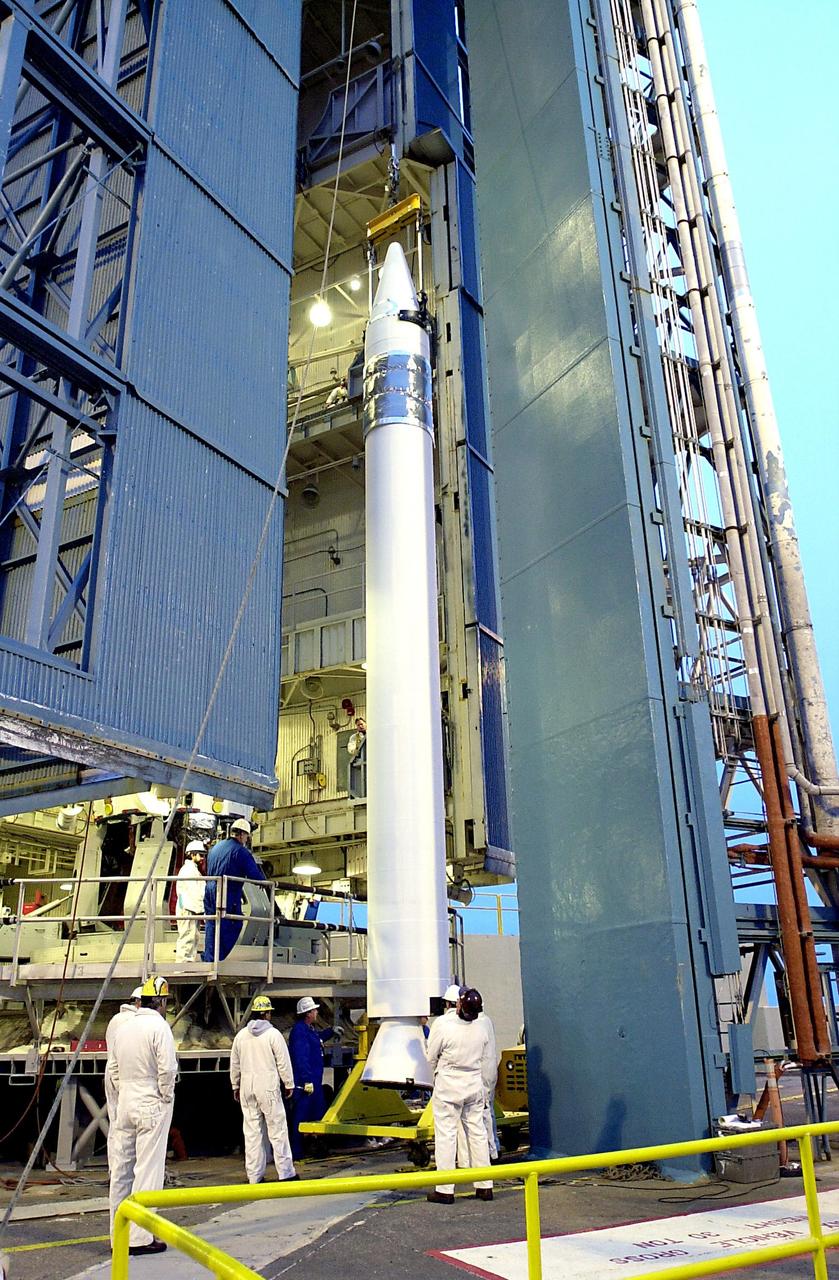
KSC-02pd2048
2002-10-24 · NASA Image and Video Library
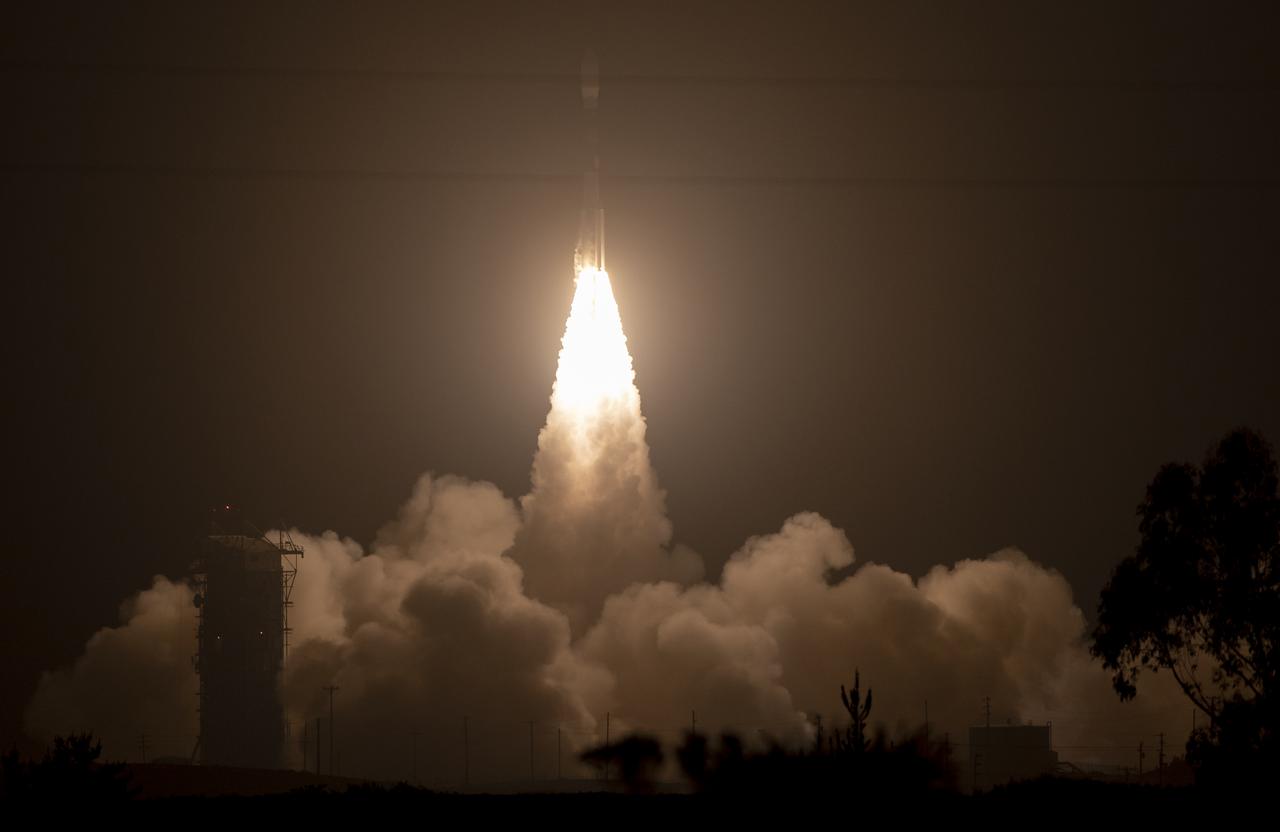
ICESat-2 Launch
2018-09-15 · NASA Image and Video Library
ICESat-2 Prelaunch
2018-09-12 · NASA Image and Video Library
Artemis III SRB Processing in RPSF
2026-06-30 · NASA Image and Video Library